Hi,
I have enabled zedx positional tracking Gen3 and im using it as ground truth to provide accurate speed to the gimbal but i also have wheel encoders and when i try to compare the speeds then VIO is quite noisy and isnt giving constant values ..is there any way i can tune the parameters because the values are totally wrong when the fact that my code which calculates the optical Flow is giving immaculate values ..
Hi,
Thanks for the report. Before tuning parameters, could you share a few things so we can pinpoint the cause?
-
Your exact SDK version and setup: please run
ZED_Diagnosticand attach the generated report. -
How you compute speed from the tracking output: a short snippet showing your
getPosition()call, theREFERENCE_FRAMEused, and whether you differentiate the pose yourself or readsl::Pose.twist, plus yourPositionalTrackingParameters(enable_imu_fusion,enable_pose_smoothing,enable_area_memory,enable_2d_ground_mode) and grab rate. -
If possible, an SVO2 recording of a representative run (60+ seconds) so we can replay the tracking on our side, ideally with a plot or CSV of VIO speed vs wheel-encoder speed.
Best regards,
Tristan
the sdk version is 5.2.3 and for the speed im just using positional tracking and then subscribing to field twist.twist.linear.x
will record the bag and drop here tomorrow
config/common_stereo.yaml
Common parameters to Stereolabs ZED Stereo cameras
/**:
ros__parameters:
use_sim_time: false # Set to true only if there is a publisher for the simulated clock to the /clock topic. Normally used in simulation mode.
    simulation:
        sim_enabled: false # Set to `true` to enable the simulation mode and connect to a simulation server
        sim_address: '127.0.0.1' # The connection address of the simulation server. See the documentation of the supported simulation plugins for more information.
        sim_port: 30000 # The connection port of the simulation server. See the documentation of the supported simulation plugins for more information.

    svo:
        use_svo_timestamps: true # Use the SVO timestamps to publish data. If false, data will be published at the system time.
        publish_svo_clock: false # [overwritten by launch file options] When use_svo_timestamps is true allows to publish the SVO clock to the `/clock` topic. This is useful for synchronous rosbag playback.
        svo_loop: false # Enable loop mode when using an SVO as input source. NOTE: ignored if SVO timestamping is used
        svo_realtime: false # if true the SVO will be played trying to respect the original framerate eventually skipping frames, otherwise every frame will be processed respecting the `pub_frame_rate` setting
        play_from_frame: 0 # Start playing the SVO from a specific frame
        replay_rate: 1.0 # Replay rate for the SVO when not used in realtime mode (between [0.10-5.0])

    general:
        camera_timeout_sec: 5
        camera_max_reconnect: 5
        camera_flip: false
        self_calib: true # Enable the self-calibration process at camera opening. See https://www.stereolabs.com/docs/api/structsl_1_1InitParameters.html#affeaa06cfc1d849e311e484ceb8edcc5
        serial_number: 0 # overwritten by launch file
        pub_resolution: 'CUSTOM' # The resolution used for image and depth map publishing. 'NATIVE' to use the same `general.grab_resolution` - `CUSTOM` to apply the `general.pub_downscale_factor` downscale factory to reduce bandwidth in transmission
        pub_downscale_factor: 2.0 # rescale factor used to rescale image before publishing when 'pub_resolution' is 'CUSTOM'
        grab_compute_capping_fps: 45.0 # Define a computation upper limit to the grab frequency. This can be useful to get a known constant fixed rate or limit the computation load while keeping a short exposure time by setting a high camera capture framerate. If set to 0, the grab compute capping will be disabled and the ZED SDK will process data at the grab rate.
        pub_frame_rate: 60.0 # [DYNAMIC] Frequency of publishing of visual images and depth data (not the Point Cloud, see 'depth.point_cloud_freq'). This value must be equal or less than the camera framerate.
        enable_image_validity_check: 1 # [SDK5 required] Sets the image validity check. If set to 1, the SDK will check if the frames are valid before processing.
        gpu_id: -1
        optional_opencv_calibration_file: '' # Optional path where the ZED SDK can find a file containing the calibration information of the camera computed by OpenCV. Read the ZED SDK documentation for more information: https://www.stereolabs.com/docs/api/structsl_1_1InitParameters.html#a9eab2753374ef3baec1d31960859ba19
        async_image_retrieval: false # If set to true will camera image retrieve at a framerate different from \ref grab() application framerate. This is useful for recording SVO or sending camera stream at different rate than application.
        publish_status: true # Advertise the status topics that are published only if a node subscribes to them
        # Other parameters are defined, according to the camera model, in the 'zed.yaml', 'zedm.yaml', 'zed2.yaml', 'zed2i.yaml'
        # 'zedx.yaml', 'zedxmini.yaml', 'virtual.yaml' files

    video:
        saturation: 4 # [DYNAMIC]
        sharpness: 4 # [DYNAMIC]
        gamma: 8 # [DYNAMIC]
        auto_exposure_gain: true # [DYNAMIC]
        exposure: 80 # [DYNAMIC]
        gain: 80 # [DYNAMIC]
        auto_whitebalance: true # [DYNAMIC]
        whitebalance_temperature: 42 # [DYNAMIC] - [28,65] x100 - works only if `auto_whitebalance` is false
        enable_24bit_output: false # [SDK >= 5.1] Enable BGR 24-bit output for lower bandwidth usage. If false, BGRA 32-bit output is used (old way before SDK v5.1)
        publish_rgb: true # Advertise the RGB image topics that are published only if a node subscribes to them
        publish_left_right: false # Advertise the left and right image topics that are published only if a node subscribes to them
        publish_raw: false # Advertise the raw image topics that are published only if a node subscribes to them
        publish_gray: false # Advertise the gray image topics that are published only if a node subscribes to them
        publish_stereo: false # Advertise the stereo image topic that is published only if a node subscribes to it
        # Other parameters are defined, according to the camera model, in the 'zed.yaml', 'zedm.yaml', 'zed2.yaml', 'zed2i.yaml'
        # 'zedx.yaml', 'zedxmini.yaml', 'virtual.yaml' files

    sensors:
        publish_imu_tf: false # [overwritten by launch file options] enable/disable the IMU TF broadcasting
        sensors_image_sync: true # Synchronize Sensors messages with latest published video/depth message
        sensors_pub_rate: 100. # frequency of publishing of sensors data. MAX: 400. - MIN: grab rate
        publish_imu: true # Advertise the IMU topic that is published only if a node subscribes to it
        publish_imu_raw: false # Advertise the raw IMU topic that is published only if a node subscribes to it
        publish_cam_imu_transf: false # Advertise the CAMERA-IMU transformation topic that is published only if a node subscribes to it
        publish_mag: false # Advertise the magnetometer topic that is published only if a node subscribes to it
        publish_baro: false # Advertise the barometer topic that is published only if a node subscribes to it
        publish_temp: false # Advertise the temperature topics that are published only if a node subscribes to them

    region_of_interest:
        automatic_roi: true # Enable the automatic ROI generation to automatically detect part of the robot in the FoV and remove them from the processing. Note: if enabled the value of `manual_polygon` is ignored
        depth_far_threshold_meters: 2.5 # Filtering how far object in the ROI should be considered, this is useful for a vehicle for instance
        image_height_ratio_cutoff: 0.5 # By default consider only the lower half of the image, can be useful to filter out the sky
        #manual_polygon: '[]' # A polygon defining the ROI where the ZED SDK perform the processing ignoring the rest. Coordinates must be normalized to '1.0' to be resolution independent.
        #manual_polygon: '[[0.25,0.33],[0.75,0.33],[0.75,0.5],[0.5,0.75],[0.25,0.5]]' # A polygon defining the ROI where the ZED SDK perform the processing ignoring the rest. Coordinates must be normalized to '1.0' to be resolution independent.
        #manual_polygon: '[[0.25,0.25],[0.75,0.25],[0.75,0.75],[0.25,0.75]]' # A polygon defining the ROI where the ZED SDK perform the processing ignoring the rest. Coordinates must be normalized to '1.0' to be resolution independent.
        #manual_polygon: '[[0.5,0.25],[0.75,0.5],[0.5,0.75],[0.25,0.5]]' # A polygon defining the ROI where the ZED SDK perform the processing ignoring the rest. Coordinates must be normalized to '1.0' to be resolution independent.
        apply_to_depth: true # Apply ROI to depth processing
        apply_to_positional_tracking: false # Apply ROI to positional tracking processing
        apply_to_object_detection: true # Apply ROI to object detection processing
        apply_to_body_tracking: true # Apply ROI to body tracking processing
        apply_to_spatial_mapping: false # Apply ROI to spatial mapping processing
        publish_roi_mask: false # Advertise the ROI mask image topic that is published only if a node subscribes to it

    depth:
        depth_mode: 'NEURAL' # Matches the ZED SDK setting: 'NONE', 'NEURAL_LIGHT', 'NEURAL', 'NEURAL_PLUS' - Note: if 'NONE' all the modules that requires depth extraction are disabled by default (Pos. Tracking, Obj. Detection, Mapping, ...)
        depth_stabilization: 30 # Forces positional tracking to start if major than 0 - Range: [0,100]
        openni_depth_mode: false # 'false': 32bit float [meters], 'true': 16bit unsigned int [millimeters]
        point_cloud_freq: 60.0 # [DYNAMIC] Frequency of the pointcloud publishing. This value must be equal or less than the camera framerate.
        point_cloud_res: 'COMPACT' # The resolution used for point cloud publishing - 'COMPACT'-Standard resolution. Optimizes processing and bandwidth, 'REDUCED'-Half resolution. Low processing and bandwidth requirements
        depth_confidence: 95 # [DYNAMIC]
        depth_texture_conf: 100 # [DYNAMIC]
        remove_saturated_areas: true # [DYNAMIC]
        publish_depth_map: true # Advertise the depth map topics that are published only if a node subscribes to them
        publish_depth_info: false # Advertise the depth info topic that is published only if a node subscribes to it
        publish_point_cloud: true # Advertise the point cloud topic that is published only if a node subscribes to it
        publish_depth_confidence: false # Advertise the depth confidence topic that is published only if a node subscribes to it
        publish_disparity: false # Advertise the disparity topic that is published only if a node subscribes to it
        # Other parameters are defined, according to the camera model, in the 'zed.yaml', 'zedm.yaml', 'zed2.yaml', 'zed2i.yaml'
        # 'zedx.yaml', 'zedxmini.yaml', 'virtual.yaml' files

    pos_tracking:
        pos_tracking_enabled: true # True to enable positional tracking from start
        pos_tracking_mode: 'GEN_3' # Matches the ZED SDK setting: 'GEN_1', 'GEN_2', 'GEN_3'
        imu_fusion: true # enable/disable IMU fusion. When set to false, only the optical odometry will be used.
        publish_tf: false # [overwritten by launch file options] publish `odom -> camera_link` TF
        publish_map_tf: false # [overwritten by launch file options] publish `map -> odom` TF
        map_frame: 'map'
        odometry_frame: 'odom'
        area_memory: false # Enable to detect loop closure
        area_file_path: '' # Path to the area memory file for relocalization and loop closure in a previously explored environment.
        enable_localization_only: false # If true, the camera will only localize in the loaded area memory without updating the map with new information.
        save_area_memory_on_closing: false # Save Area memory before closing the camera if `area_file_path` is not empty. You can also use the `save_area_memory` service to save the area memory at any time.
        reset_odom_with_loop_closure: true # Re-initialize odometry to the last valid pose when loop closure happens (reset camera odometry drift)
        publish_3d_landmarks: false # Publish 3D landmarks used by the positional tracking algorithm
        publish_lm_skip_frame: 5 # Publish the landmarks every X frames to reduce bandwidth. Set to 0 to publish all landmarks
        depth_min_range: 0.0 # Set this value for removing fixed zones of the robot in the FoV of the camerafrom the visual odometry evaluation
        set_as_static: false # If 'true' the camera will be static and not move in the environment
        set_gravity_as_origin: true # If 'true' align the positional tracking world to imu gravity measurement. Keep the yaw from the user initial pose.
        floor_alignment: false # Enable to automatically calculate camera/floor offset
        initial_base_pose: [0.0, 0.0, 0.0, 0.0, 0.0, 0.0] # Initial position of the `camera_link` frame in the map -> [X, Y, Z, R, P, Y]
        path_pub_rate: 2.0 # [DYNAMIC] - Camera trajectory publishing frequency
        path_max_count: -1 # use '-1' for unlimited path size
        two_d_mode: false # Force navigation on a plane. If true the Z value will be fixed to 'fixed_z_value', roll and pitch to zero
        fixed_z_value: 0.0 # Value to be used for Z coordinate if `two_d_mode` is true
        transform_time_offset: 0.0 # The value added to the timestamp of `map->odom` and `odom->camera_link` transform being generated
        reset_pose_with_svo_loop: true # Reset the camera pose the `initial_base_pose` when the SVO loop is enabled and the SVO playback reaches the end of the file.
        publish_odom_pose: true # Advertise the odometry and pose topics that are published only if a node subscribes to them
        publish_pose_cov: false # Advertise the pose with covariance topic that is published only if a node subscribes to it
        publish_cam_path: false # Advertise the camera odometry and pose path topics that are published only if a node subscribes to them

    gnss_fusion:
        gnss_fusion_enabled: true # fuse 'sensor_msg/NavSatFix' message information into pose data
        gnss_fix_topic: '/fix' # Name of the GNSS topic of type NavSatFix to subscribe [Default: '/gps/fix']
        gnss_zero_altitude: false # Set to `true` to ignore GNSS altitude information
        h_covariance_mul: 1.0 # Multiplier factor to be applied to horizontal covariance of the received fix (plane X/Y)
        v_covariance_mul: 1.0 # Multiplier factor to be applied to vertical covariance of the received fix (Z axis)
        publish_utm_tf: true # Publish `utm` -> `map` TF
        broadcast_utm_transform_as_parent_frame: false # if 'true' publish `utm` -> `map` TF, otherwise `map` -> `utm`
        enable_reinitialization: false # determines whether reinitialization should be performed between GNSS and VIO fusion when a significant disparity is detected between GNSS data and the current fusion data. It becomes particularly crucial during prolonged GNSS signal loss scenarios.
        enable_rolling_calibration: true # If this parameter is set to true, the fusion algorithm will used a rough VIO / GNSS calibration at first and then refine it. This allow you to quickly get a fused position.
        enable_translation_uncertainty_target: false # When this parameter is enabled (set to true), the calibration process between GNSS and VIO accounts for the uncertainty in the determined translation, thereby facilitating the calibration termination. The maximum allowable uncertainty is controlled by the 'target_translation_uncertainty' parameter.
        gnss_vio_reinit_threshold: 5.0 # determines the threshold for GNSS/VIO reinitialization. If the fused position deviates beyond out of the region defined by the product of the GNSS covariance and the gnss_vio_reinit_threshold, a reinitialization will be triggered.
        target_translation_uncertainty: 0.1 # defines the target translation uncertainty at which the calibration process between GNSS and VIO concludes. By default, the threshold is set at 10 centimeters.
        target_yaw_uncertainty: 0.1 # defines the target yaw uncertainty at which the calibration process between GNSS and VIO concludes. The unit of this parameter is in radian. By default, the threshold is set at 0.1 radians.

    mapping:
        mapping_enabled: false # True to enable mapping t # Pand fused point cloud pubblication
        resolution: 0.05 # maps resolution in meters [min: 0.01f - max: 0.2f]
        max_mapping_range: 5.0 # maximum depth range while mapping in meters (-1 for automatic calculation) [2.0, 20.0]
        fused_pointcloud_freq: 1.0 # frequency of the publishing of the fused colored point cloud
        clicked_point_topic: '/clicked_point' # Topic published by Rviz when a point of the cloud is clicked. Used for plane detection
        pd_max_distance_threshold: 0.15 # Plane detection: controls the spread of plane by checking the position difference.
        pd_normal_similarity_threshold: 15.0 # Plane detection: controls the spread of plane by checking the angle difference.
        publish_det_plane: false # Advertise the plane detection topics that is published only if a node subscribes to it

    object_detection:
        od_enabled: false # True to enable Object Detection
        enable_tracking: true # Whether the object detection system includes object tracking capabilities across a sequence of images.
        detection_model: 'MULTI_CLASS_BOX_FAST' # 'MULTI_CLASS_BOX_FAST', 'MULTI_CLASS_BOX_MEDIUM', 'MULTI_CLASS_BOX_ACCURATE', 'PERSON_HEAD_BOX_FAST', 'PERSON_HEAD_BOX_ACCURATE', 'CUSTOM_YOLOLIKE_BOX_OBJECTS'
        max_range: 20.0 # [m] Upper depth range for detections.The value cannot be greater than 'depth.max_depth'
        filtering_mode: 'NMS3D' # Filtering mode that should be applied to raw detections: 'NONE', 'NMS3D', 'NMS3D_PER_CLASS'
        prediction_timeout: 2.0 # During this time [sec], the object will have OK state even if it is not detected. Set this parameter to 0 to disable SDK predictions
        allow_reduced_precision_inference: false # Allow inference to run at a lower precision to improve runtime and memory usage
        # Other parameters are defined in the 'object_detection.yaml' and 'custom_object_detection.yaml' files

    body_tracking:
        bt_enabled: false # True to enable Body Tracking
        model: 'HUMAN_BODY_MEDIUM' # 'HUMAN_BODY_FAST', 'HUMAN_BODY_MEDIUM', 'HUMAN_BODY_ACCURATE'
        body_format: 'BODY_38' # 'BODY_18','BODY_34','BODY_38'
        allow_reduced_precision_inference: false # Allow inference to run at a lower precision to improve runtime and memory usage
        max_range: 15.0 # [m] Defines a upper depth range for detections
        body_kp_selection: 'FULL' # 'FULL', 'UPPER_BODY'
        enable_body_fitting: false # Defines if the body fitting will be applied
        enable_tracking: true # Defines if the object detection will track objects across images flow
        prediction_timeout_s: 0.5 # During this time [sec], the skeleton will have OK state even if it is not detected. Set this parameter to 0 to disable SDK predictions
        confidence_threshold: 50.0 # [DYNAMIC] - Minimum value of the detection confidence of skeleton key points [0,99]
        minimum_keypoints_threshold: 5 # [DYNAMIC] - Minimum number of skeleton key points to be detected for a valid skeleton

    stream_server:
        stream_enabled: false # enable the streaming server when the camera is open
        codec: 'H264' # different encoding types for image streaming: 'H264', 'H265'
        port: 30000 # Port used for streaming. Port must be an even number. Any odd number will be rejected.
        bitrate: 20000 # [1000 - 60000] Streaming bitrate (in Kbits/s) used for streaming. See https://www.stereolabs.com/docs/api/structsl_1_1StreamingParameters.html#a873ba9440e3e9786eb1476a3bfa536d0
        gop_size: -1 # [max 256] The GOP size determines the maximum distance between IDR/I-frames. Very high GOP size will result in slightly more efficient compression, especially on static scenes. But latency will increase.
        adaptative_bitrate: false # Bitrate will be adjusted depending the number of packet dropped during streaming. If activated, the bitrate can vary between [bitrate/4, bitrate].
        chunk_size: 16084 # [1024 - 65000] Stream buffers are divided into X number of chunks where each chunk is chunk_size bytes long. You can lower chunk_size value if network generates a lot of packet lost: this will generates more chunk for a single image, but each chunk sent will be lighter to avoid inside-chunk corruption. Increasing this value can decrease latency.
        target_framerate: 30 # Framerate for the streaming output. This framerate must be below or equal to the camera framerate. Allowed framerates are 15, 30, 60 or 100 if possible. Any other values will be discarded and camera FPS will be taken.

    advanced: # WARNING: do not modify unless you are confident of what you are doing
        # Reference documentation: https://man7.org/linux/man-pages/man7/sched.7.html
        thread_sched_policy: 'SCHED_BATCH' # 'SCHED_OTHER', 'SCHED_BATCH', 'SCHED_FIFO', 'SCHED_RR' - NOTE: 'SCHED_FIFO' and 'SCHED_RR' require 'sudo'
        thread_grab_priority: 50 # ONLY with 'SCHED_FIFO' and 'SCHED_RR' - [1 (LOW) z-> 99 (HIGH)] - NOTE: 'sudo' required
        thread_sensor_priority: 70 # ONLY with 'SCHED_FIFO' and 'SCHED_RR' - [1 (LOW) z-> 99 (HIGH)] - NOTE: 'sudo' required
        thread_pointcloud_priority: 60 # ONLY with 'SCHED_FIFO' and 'SCHED_RR' - [1 (LOW) z-> 99 (HIGH)] - NOTE: 'sudo' required

    debug:
        sdk_verbose: 1 # Set the verbose level of the ZED SDK
        sdk_verbose_log_file: '' # Path to the file where the ZED SDK will log its messages. If empty, no file will be created. The log level can be set using the `sdk_verbose` parameter.
        use_pub_timestamps: false # Use the current ROS time for the message timestamp instead of the camera timestamp. This is useful to test data communication latency.
        debug_common: false
        debug_grab: false
        debug_sim: false
        debug_video_depth: false
        debug_camera_controls: false
        debug_point_cloud: false
        debug_tf: false
        debug_positional_tracking: false
        debug_gnss: false
        debug_sensors: false
        debug_mapping: false
        debug_terrain_mapping: false
        debug_object_detection: false
        debug_body_tracking: false
        debug_roi: false
        debug_streaming: false
        debug_advanced: false
        debug_nitros: false
        disable_nitros: false # If available, disable NITROS usage for debugging and testing purposes
Hi,
Thanks for the config, that helps a lot. One thing stands out: you have gnss_fusion.gnss_fusion_enabled: true. With that setting, the odometry topic (including the twist you subscribe to) is produced by the SDK Fusion module rather than directly by the camera’s visual-inertial tracking, and any GNSS data on /fix will inject corrections into it. Could you try setting gnss_fusion_enabled: false (the default) and check whether the velocity becomes consistent with your wheel encoders? If you do need GNSS fusion, this test still tells us which side the noise comes from.
Two more suggestions worth a quick A/B while you are at it: try pos_tracking_mode: 'GEN_1', which is optimized for smooth VIO, and consider upgrading to SDK 5.4.x, since 5.4.0/5.4.1 include fixes relevant to ZED X velocity smoothness (IMU thermal compensation and frame timestamp jitter).
The bag will be very useful. If you can also record a short SVO2 of the same run (via ZED_Explorer or by enabling SVO recording in the wrapper), we can replay the tracking on our side with different settings.
Best regards,
Tristan
Thanks for the Reply
so right now im testing indoors and im not turning on GNSS so the topic never pops in the first place …but eventually i will be using GNSS ..
attaching u a bag ..
1100_0.mcap (986.4 KB)
metadata.yaml (1.2 KB)
and its GEN3 ..in the bag.
Hi,
Thanks for the bag. Interestingly the twist itself looks smooth here (steady plateau around 0.037 m/s), but it contradicts the pose in the same messages: integrating the twist gives about 1.5 m of travel while the pose only moves about 8 cm, sideways. To find out which one is wrong, could you tell us what the robot actually did during this run (commanded speed and wheel encoder distance)?
Two config notes: this bag looks like it ran with two_d_mode: true (z and roll/pitch rates are exactly zero), which differs from the config you sent, so can you please confirm the parameters used? Also set gnss_fusion_enabled: false for indoor tests, since that parameter alone routes odometry through the Fusion module even with no GNSS fix.
An SVO2 of the same run would let us replay it here and compare GEN_1 vs GEN_3 directly.
Best regards,
Tristan
Hi,
sorry the bag i sent was a fused baf of wheel encoders.. i am attaching u the bag that has separate zed positional tracking topic ..
Also the
metadata.yaml (2.6 KB)
rpm_1300_0.mcap (3.0 MB)
also for your understanding the camera is placed upside down facing the ground and the speeds are in the linear.z component (forward speed ) and the speed its running is 43.3mm/sec or 0.043m/sec to be very precise in creeper1 gear and the thing is the positional tracking isnt stable it has humongous noise ..
the bag i attached has separate topic od /zed/zed_node/odom ..
and also is there any way where i can write my own positional tracking or say add few features like histogram equalisation using the zeds wrapper ??
Hi,
Your ZED tracking is accurate: 46.6 mm/s vs your encoders’ 44.8 mm/s, distance matches within 10%. The scatter you’re seeing is normal instantaneous VIO noise — fix it with a low-pass filter (1–3 s moving average) and enable_pose_smoothing: true. Also try pos_tracking_mode: ‘GEN_1’, and depth_mode: ‘NEURAL_LIGHT’ to reduce the publishing gaps we saw.
Histogram equalization can’t be injected into the SDK’s tracking pipeline (closed, reads directly from camera) — only exposure/gain/gamma are exposed. You can still run your own processing on the published image topics separately.
Best regards,
Tristan
zed_odom_corrected.csv (8.2 MB)
if you check the csv the zed keeps giving the sudden spikes in linear speed …
the ground speed is 0.055m/sec but the positional tracking keeps giving fluctuations over the period which is bad for the ekf ..and also the gnss was disabled on the csv i just shared ..
abd that /zed/odom_corrected is just a remapped topic which gives the speed in linear.x component … as the camera is facing the ground
Hi Mohammed,
Thank you for the CSV, it was the missing piece. Your total travelled distance is accurate, but you were right about the per frame output: it shows a repeating pattern that is not sensor noise. We have logged it internally for the SDK team and I will come back to you with their finding.
To help them reproduce it, could you please send an SVO2 of a similar run, plus a bag of the raw odometry topic rather than the republished one?
Best,
Tristan Leduc
StereoLabs Support
Hey,
i will record a bag and will attach it and send it to you for the original topic
Hi Mohammed,
The parameter read is correct, but the patch will not take effect as written. In startPosTracking(), on the wrapper tag matching your SDK 5.2.3, the code sets mPoseSmoothing = false and then assigns it to ptParams.enable_pose_smoothing, so your value is read, logged as TRUE, and overwritten before it reaches the SDK. Delete that assignment and keep yours. You also do not need the launch argument, the wrapper already accepts param_overrides:="pos_tracking.enable_pose_smoothing:=true".
Does that answer your question?
Best,
Tristan Leduc
StereoLabs Support
Right now the setup goes this way : ZED ROS 2 wrapper running inside a Docker container with ROS 2 Jazzy and ZED SDK 5.4.1, while my host system runs ROS 2 Humble with a separate ~/Zed_ws; the Docker container keeps the original working ZED 5.4.1 wrapper/components and I mount only the configuration directory from my host ~/Zed_ws/src/zed-ros2-wrapper/zed_wrapper/config into /root/ros2_ws/install/zed_wrapper/share/zed_wrapper/config, so the YAML configuration used by the Docker-based ZED node comes from my host workspace while the ZED binaries remain unchanged in Docker. I am trying to enable positional-tracking pose smoothing, and based on your previous guidance I understand that the wrapper reads pos_tracking.enable_pose_smoothing, but in startPosTracking() the value can be overwritten by a hard-coded mPoseSmoothing = false before being assigned to ptParams.enable_pose_smoothing, so that assignment should be removed. You also mentioned that I do not need to add a custom launch argument and can instead use param_overrides:="pos_tracking.enable_pose_smoothing:=true". I tested this override in my Docker setup, but when the ZED node launched I did not see a Pose Smoothing: TRUE or similar log entry, so I would like to clarify the expected behavior: when using param_overrides:="pos_tracking.enable_pose_smoothing:=true", should the wrapper log the pose-smoothing value during node initialization/startup?
zed_zed_node_odom.csv (956.7 KB)
have attached the bag with original zed odom topics as well
Hi Mohammed,
when using
param_overrides:="pos_tracking.enable_pose_smoothing:=true", should the wrapper log the pose-smoothing value during node initialization/startup?
No, it should not, and I have to correct what was written earlier in this topic: that parameter does not exist in the ZED ROS 2 wrapper.
I checked the sources at tag v5.4.1, the same version running in your container. Pose smoothing appears in exactly three places:
zed_components/src/zed_camera/include/zed_camera_component.hpp:614→bool mPoseSmoothing = false;zed_components/src/zed_camera/src/zed_camera_component_main.cpp:4074→mPoseSmoothing = false; // Always false. Pose Smoothing is to be enabled only for VR/AR applicationszed_components/src/zed_camera/src/zed_camera_component_main.cpp:4077→ptParams.enable_pose_smoothing = mPoseSmoothing;
There is no getParam() call for pos_tracking.enable_pose_smoothing, so the parameter is never declared, never read from the YAML, and never logged. The node does not enable automatically_declare_parameters_from_overrides, so an override for an undeclared parameter is silently discarded by rclcpp. The missing log line is the expected behavior, not a side effect of your Docker configuration mount.
The parameter does not exist and is not listed in the official documentation:
Two practical consequences for your setup:
- The value is compiled in, so mounting only the
configfolder cannot change it. To test pose smoothing you must remove the assignment at line 4074 and rebuild inside the container, for examplecolcon build --packages-select zed_components; editing the sources in~/Zed_wson the host has no effect on the node running in Docker. - To verify what actually reaches the SDK, set
debug.debug_positional_tracking: true. Immediately before callingenablePositionalTracking(), the wrapper encodes the fullsl::PositionalTrackingParametersstructure to JSON and prints it, so you will see the real value ofenable_pose_smoothing.
That said, I do not expect pose smoothing to fix your case. It filters the pose to reduce jitter at the cost of responsiveness; it is recommended for AR/VR and should be disabled for real-time robotics control, as described here: Positional Tracking Settings, Enable Pose Smoothing. It would not remove the repeating per-frame pattern we identified in your data. For the EKF, the correct approach is to feed the raw odometry and do the filtering downstream, where you control the time constant.
Thank you for the CSV of the original /zed/zed_node/odom topic, it has been added to the internal report for the ZED X velocity investigation. An SVO2 recording of a similar run is still the missing piece to let the SDK team reproduce it on our side.
Hi,
dropping you an svo for your reference ..
file.zip
Hi @hamdan11
I tested your SVO with the ZED ROS2 Wrapper using the default setting and I cannot notice the problems with the speed that your described
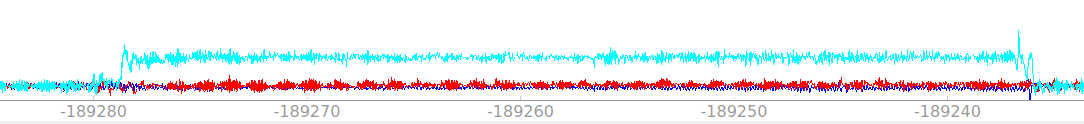
what about the per-frame pattern in my data that you observed ?? even in the csv the odom values were fluctuating .
In the odometry, speed values are estimated step by step.
The SVO clearly shows vibrations that could explain the spikes that you noticed.
The purpose of the EKF is to smooth this kind of data when it’s correctly tuned.
alright .. i got it ..
just one more clarification ..
since i want to set the exposure time manually and i did this
video: saturation: 6 # [DYNAMIC] sharpness: 6 # [DYNAMIC] gamma: 8 # [DYNAMIC] auto_exposure_gain: false # [DYNAMIC] exposure_time: 2000 exposure: 6 # [DYNAMIC]
the exposure value changed but the exposure time didnt reflect and it went to the default 16000microseconds..
i want to make it 2000microseconds …
Hi @hamdan11
That is expected with the file you modified. video.exposure_time is not a parameter of common_stereo.yaml; it is a GMSL2 specific control declared in the camera model file, zed_wrapper/config/zedx.yaml.
The launch file loads common_stereo.yaml first and then the model file, so exposure_time: 16000 in zedx.yaml always overwrites the value you wrote in the common file. Instead, video.exposure exists only in common_stereo.yaml, and this is why that one took your value.
So please move your settings to zedx.yaml:
yaml
/**:
    ros__parameters:
        video:
            auto_exposure_gain: false
            exposure_time: 2000   # [us]
            analog_gain: 1255     # [mdB]
            digital_gain: 1
Two more notes about the ZED X:
exposure_time,analog_gainanddigital_gainare the recommended manual controls for the GMSL2 cameras;exposureandgainare the legacy percentage controls, mapped to different ZED SDK settings. Please do not mix them, otherwise the last applied value wins and the result looks random. Leaveexposureandgainat their default values.- You can verify what the node really loaded with
ros2 param get /zed/zed_node video.exposure_time, and you can setdebug.debug_camera_controls: trueincommon_stereo.yamlto log every camera control that the node applies at startup.
For your use case, 2000 us is a good choice; it is well within the frame period at 30/60 FPS and the reduced motion blur normally improves the quality of the VIO estimation.
Reference documentation: ZED Stereo Node and Camera Controls.
1 Like