Hi!
I’m trying to setup the single streamer /receiver example from ZED SDK 5.4.1 on a Jetson Orin Nano Developer Kit 8GB using a ZED X paired with a ZED Link Duo capture card.
However, I’m facing some problems.
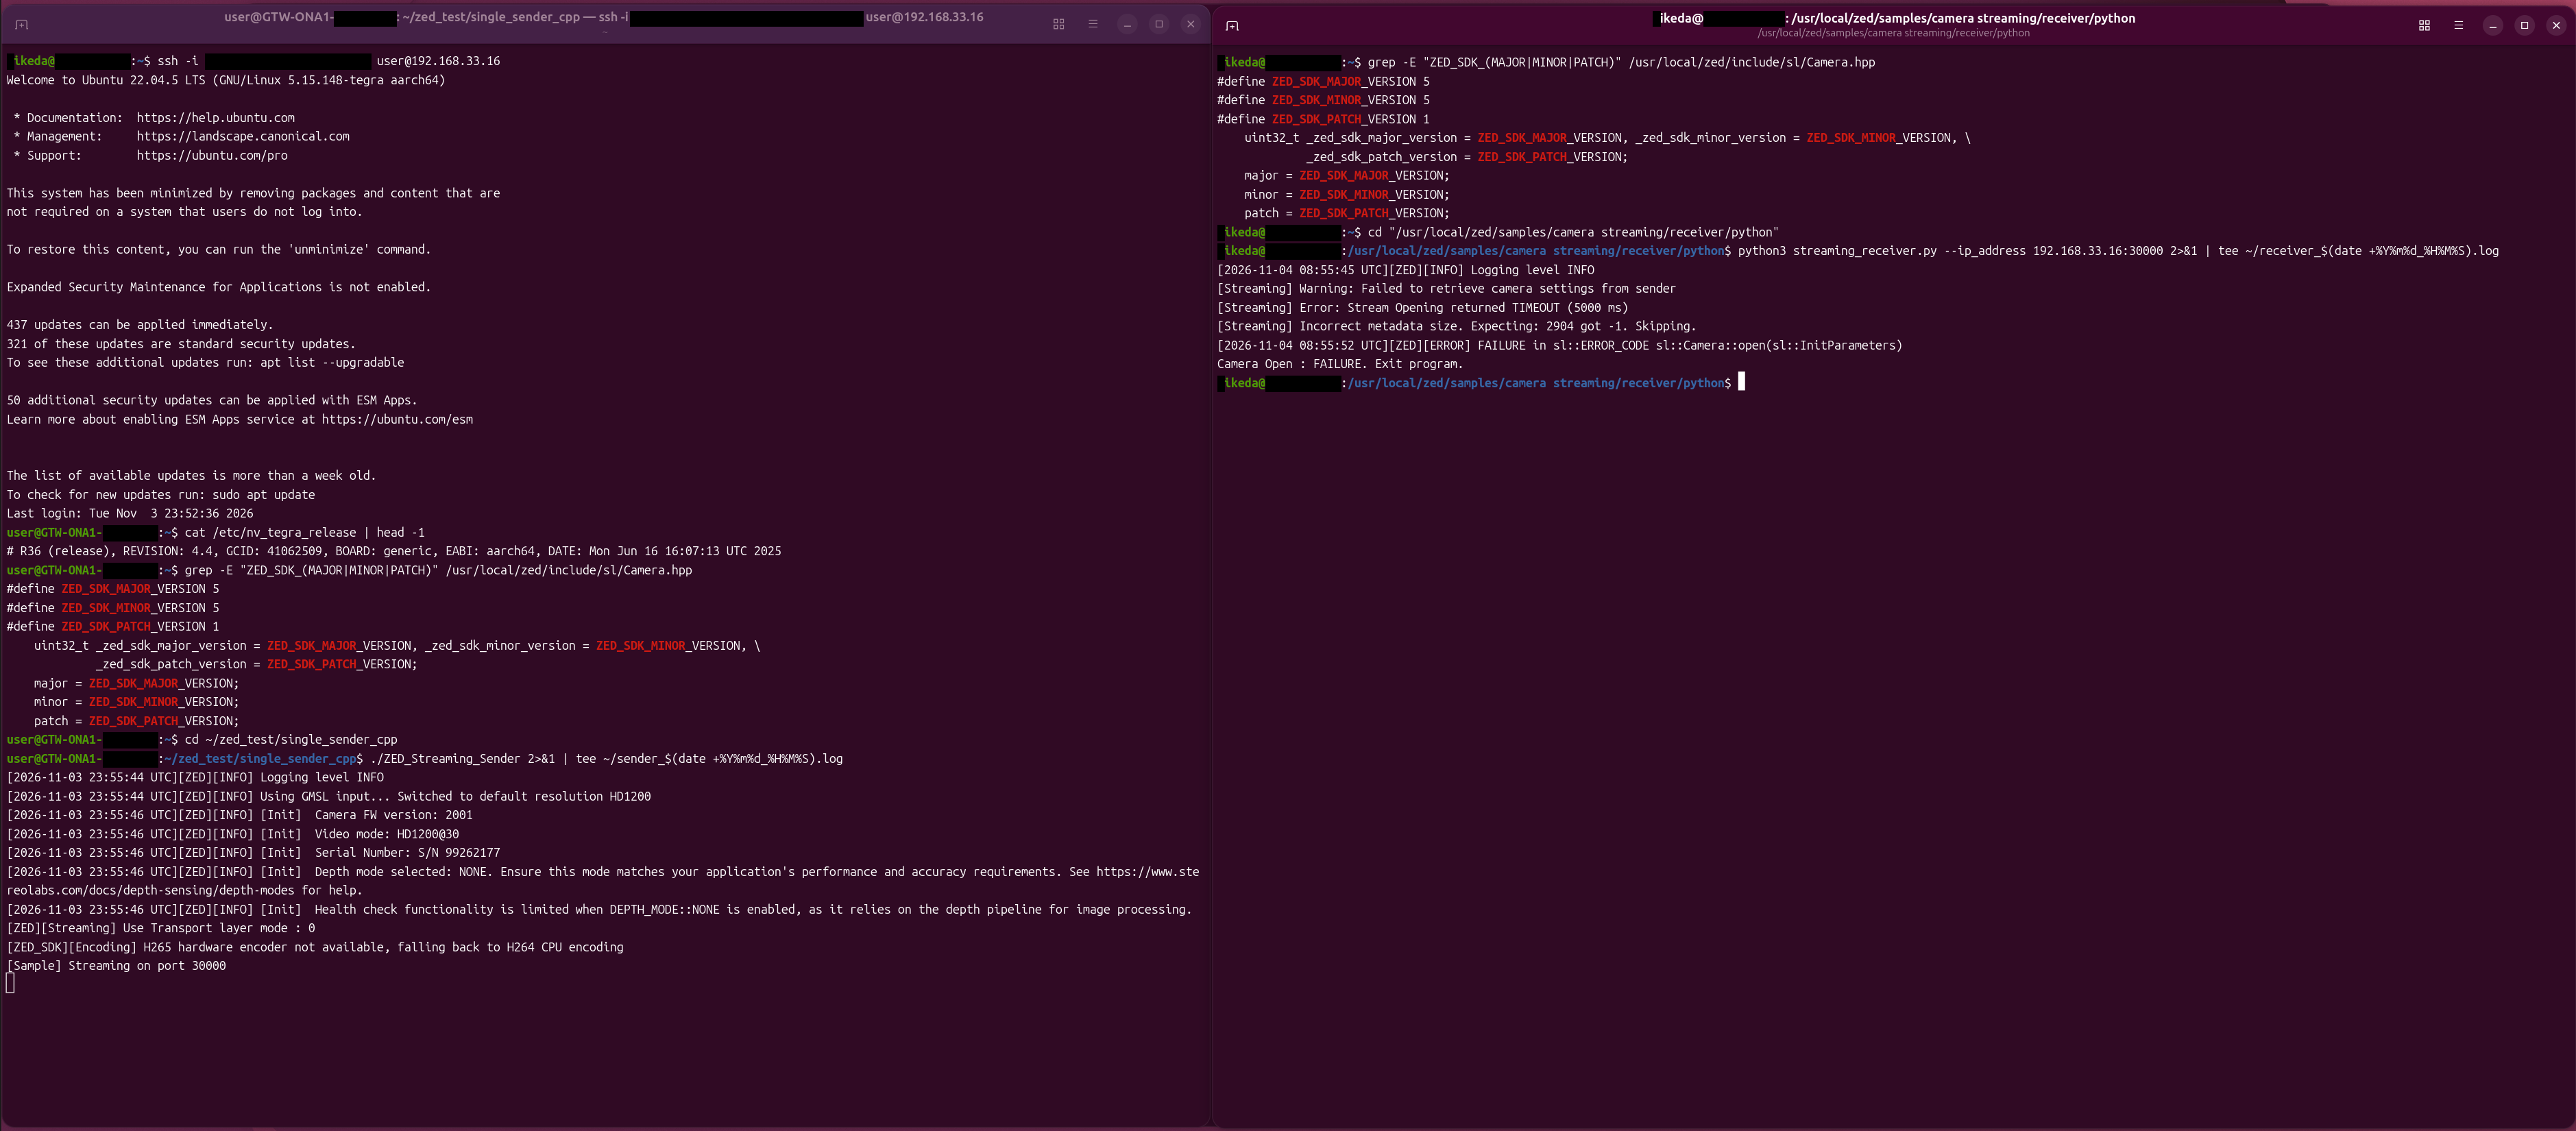
Even though I can ping the machine and the stream starts successfully:
ubuntu@ubuntu:/usr/local/zed/samples/camera streaming/receiver/python$ ping 192.168.1.103

PING 192.168.1.103 (192.168.1.103) 56(84) bytes of data.

64 bytes from 192.168.1.103: icmp_seq=1 ttl=64 time=0.410 ms

64 bytes from 192.168.1.103: icmp_seq=2 ttl=64 time=0.293 ms

^C

--- 192.168.1.103 ping statistics ---

2 packets transmitted, 2 received, 0% packet loss, time 1039ms

rtt min/avg/max/mdev = 0.293/0.351/0.410/0.058 ms

ubuntu@ubuntu:/usr/local/zed/samples/camera streaming/single_sender/python$ python3 streaming_sender.py
[Sample] Using default resolution
[2026-09-14 12:08:50 UTC][ZED][INFO] Logging level INFO
[2026-09-14 12:08:51 UTC][ZED][INFO] Using GMSL input... Switched to default resolution HD1200
[2026-09-14 12:08:51 UTC][ZED][INFO] [Init]  Camera FW version: 2001
[2026-09-14 12:08:51 UTC][ZED][INFO] [Init]  Video mode: HD1200@30
[2026-09-14 12:08:51 UTC][ZED][INFO] [Init]  Serial Number: S/N 40081464
[2026-09-14 12:08:51 UTC][ZED][INFO] [Init]  Depth mode selected: NEURAL. Ensure this mode matches your application's performance and accuracy requirements. See https://www.stereolabs.com/docs/depth-sensing/depth-modes for help.
Streaming on port  30000
[ZED][Streaming] Use Transport layer mode : 0
On the receiver side i get:
ubuntu@ubuntu:/usr/local/zed/samples/camera streaming/receiver/python$ python streaming_receiver.py --ip_address 192.168.1.103:30000
[2026-09-14 12:25:11 UTC][ZED][INFO] Logging level INFO
[Streaming] Warning: Failed to retrieve camera settings from sender
[Streaming] Error: Stream Opening returned TIMEOUT (5000 ms)
[Streaming] Incorrect metadata size. Expecting: 2904 got -1. Skipping.
[2026-09-14 12:25:18 UTC][ZED][ERROR] FAILURE in sl::ERROR_CODE sl: 
:open(sl::InitParameters)
Camera Open : FAILURE. Exit program.
This communication error remain even if I use ZED Explorer as receiver, both in the same or a different machine.
NOTE: ZED Diagnostic shows no problem, everything is fine and all checks are passed